
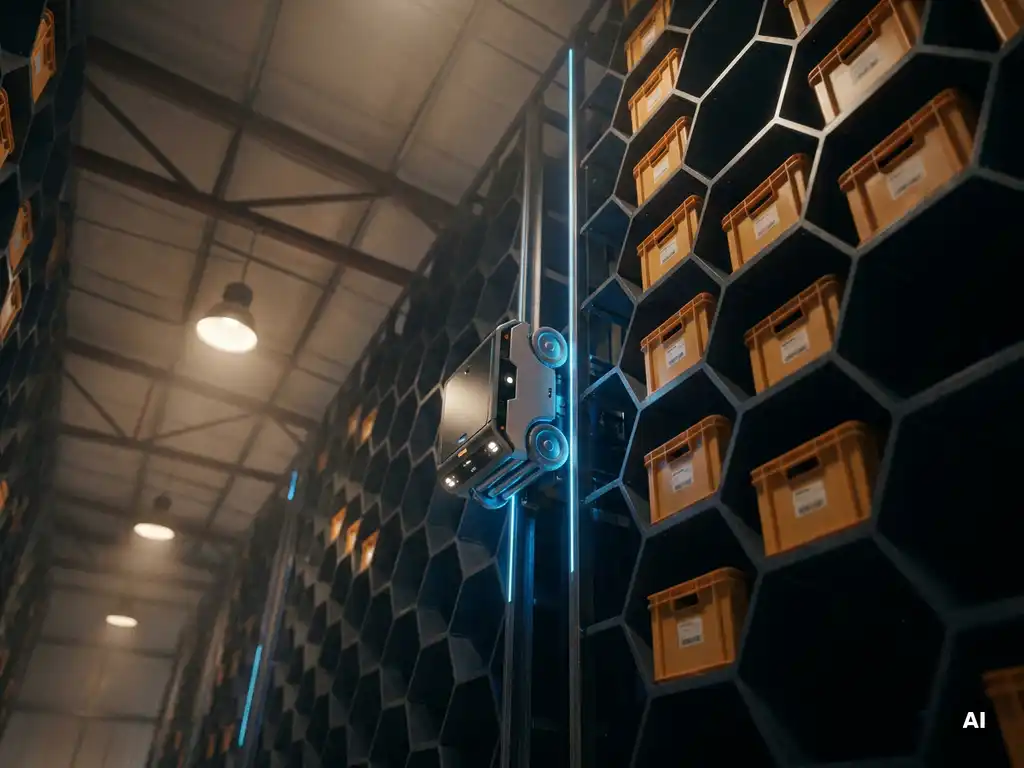
An autonomous mobile robot (AMR) in warehousing is a self-guided robotic unit that moves through a warehouse environment independently, using onboard sensors, cameras, and software to navigate, avoid obstacles, and complete tasks without fixed tracks or human direction. Unlike older automated systems that follow predefined paths, AMRs build and update a real-time map of their surroundings, allowing them to reroute dynamically when conditions change. The sections below address the most common questions warehouse engineers ask when evaluating AMR technology.
How does an autonomous mobile robot navigate a warehouse?
An autonomous mobile robot navigates a warehouse by combining onboard sensors, simultaneous localization and mapping (SLAM) algorithms, and real-time path planning software. The robot continuously scans its environment using LiDAR, depth cameras, or ultrasonic sensors, builds a spatial map, and calculates the most efficient route to its destination while detecting and avoiding people, equipment, and unexpected obstacles.
SLAM is the core technology that makes this possible. As the robot moves, it cross-references sensor data against its existing map, correcting its own position estimate and updating the map simultaneously. This means the robot does not need reflective tape, magnetic strips, or embedded floor guides to know where it is.
Most modern AMRs also connect to a fleet management layer that coordinates multiple units across the warehouse floor. This central software assigns tasks, prevents traffic conflicts, and reroutes robots around congestion points or closed aisles. The result is a mobile robot navigation system that adapts to the live state of the warehouse rather than following a fixed script.
What’s the difference between an AMR and an AGV?
The key difference between an AMR and an AGV (automated guided vehicle) is how each robot finds its way. An AGV follows a fixed, pre-installed path, typically a magnetic strip, wire, or optical track embedded in the floor. An AMR navigates freely using its own sensors and software, requiring no physical infrastructure on the floor to guide it.
This distinction has significant practical consequences for warehouse operations:
- Flexibility: AMRs can be redeployed to different areas of a warehouse without modifying the floor. AGVs require physical changes to their guidance infrastructure when routes change.
- Obstacle response: An AGV that encounters an unexpected obstacle typically stops and waits for the path to clear. An AMR reroutes around it autonomously.
- Installation complexity: AGVs require upfront infrastructure work to lay tracks or embed guidance systems. AMRs can be deployed with minimal site preparation.
- Cost profile: AGVs generally carry lower unit hardware costs but higher installation and reconfiguration costs over time. AMRs have higher initial software complexity but lower long-term adaptation costs.
For warehouses with stable, high-volume routes, an AGV can be a reliable and cost-effective choice. For environments with variable layouts, mixed traffic, or frequent operational changes, an AMR offers substantially more adaptability.
What tasks can autonomous mobile robots perform in a warehouse?
Autonomous mobile robots in warehouses can perform a wide range of material handling tasks, including goods transport between zones, order-picking support, inventory scanning, tote delivery to workstations, and replenishment of pick locations. The specific tasks an AMR can execute depend on its payload capacity, onboard attachments, and the software logic controlling it.
The most common AMR applications in warehouse automation include:
- Goods-to-person delivery: Transporting shelving units or totes directly to a human picker at a fixed workstation, eliminating walking time.
- Zone-to-zone transport: Moving inventory or orders between receiving, storage, picking, packing, and dispatch areas.
- Inventory cycle counting: Scanning barcodes or RFID tags during transit to update stock records without dedicated counting shifts.
- Replenishment: Restocking pick faces or forward-pick locations from bulk storage automatically.
- Sortation support: Delivering sorted orders to the correct packing or dispatch lane.
AMRs are most effective when combined with a broader warehouse automation strategy. In AS/RS environments, for example, robots handling vertical storage and retrieval can work alongside floor-level AMRs to move totes from the storage system to packing stations, creating an end-to-end automated flow.
How do AMRs integrate with warehouse management systems?
AMRs integrate with warehouse management systems (WMS) through software APIs, most commonly REST APIs or middleware platforms that translate WMS task instructions into robot commands. The WMS generates a task, such as retrieving a specific tote or transporting an order to a packing station, and the AMR fleet management software receives that task and assigns it to the most suitable available robot.
In practice, integration depth varies. At a basic level, the WMS sends pick or transport tasks and receives completion confirmations. At a deeper level, the AMR system shares real-time location data, battery status, and task queue information back to the WMS, enabling dynamic reprioritization and better labor coordination across the facility.
Most enterprise WMS platforms and warehouse execution systems (WES) now support standard robot integration protocols, reducing the custom development burden. Vendors that build their control software around open APIs simplify this process further, allowing the AMR layer to slot into an existing technology stack without requiring a full system replacement. When evaluating any warehouse automation platform, confirming API compatibility with your current WMS is one of the first technical checks to complete.
What are the limitations of autonomous mobile robots in warehouses?
Autonomous mobile robots have real limitations that engineers must account for before deployment. The most significant constraints are payload capacity, navigation performance in dense or dynamic environments, vertical storage access, and throughput ceilings when floor space is limited. AMRs excel at horizontal movement but cannot, by design, utilize vertical warehouse height for storage.
Key limitations to evaluate include:
- Storage density: Floor-based AMR systems keep inventory at low heights, consuming large amounts of floor space. As SKU counts grow, this becomes a significant footprint constraint.
- Throughput ceiling: Adding more AMRs to a fixed floor area eventually creates congestion. Traffic management software mitigates this, but physical space limits the number of robots that can operate simultaneously without interference.
- Environmental sensitivity: AMR sensors can struggle in environments with highly reflective surfaces, heavy dust, dramatic lighting changes, or very narrow aisles. Site conditions must be assessed carefully before deployment.
- Vertical utilization: Standard AMRs do not climb or access elevated storage positions. Warehouses with high ceilings cannot leverage that vertical space through AMRs alone.
- Dependency on floor quality: Uneven floors, debris, or surface damage can impair navigation accuracy and robot stability.
These limitations are why many high-density operations combine floor-level AMR transport with vertical AS/RS systems, using each technology where it performs best rather than relying on a single robot type to solve every challenge.
When should a warehouse choose an AMR-based system?
A warehouse should choose an AMR-based system when it needs flexible, scalable floor-level transport, has variable workflows that change frequently, or wants to automate without installing fixed infrastructure. AMRs are a strong fit for operations with moderate storage density requirements, wide aisles, and a primary need to reduce human travel time across the floor.
Specific conditions that favor an AMR deployment include:
- Frequent layout changes or seasonal operational shifts that would make fixed-path AGVs impractical
- Goods-to-person workflows where reducing picker walking distance is the primary efficiency target
- Facilities that want to phase automation in incrementally, starting with transport and expanding over time
- Operations with relatively low building heights where vertical storage density is not a priority
Conversely, warehouses with very high SKU counts, limited floor space, tall buildings, or aggressive throughput targets often find that AMRs alone cannot deliver the required storage density or order rate. In these cases, a three-dimensional AS/RS approach, where robots access storage vertically rather than only horizontally, addresses the constraints that floor-level AMRs cannot.
The right choice depends on the specific balance between storage density needs, throughput targets, available footprint, and how frequently the operation expects to change. Evaluating those four variables together, rather than focusing on robot type alone, leads to better long-term system decisions.
How Hexxabotics addresses the limitations of standard AMR systems
Hexxabotics is a next-generation AS/RS designed specifically to overcome the storage density and throughput constraints that floor-level AMR systems cannot resolve. Where standard AMRs are limited to horizontal movement and low-height storage, the Hexxabotics system uses autonomous Hexxabots that navigate beneath the hexagonal grid and climb vertically inside storage towers to access every tote directly, up to 16 meters in height.
- Maximum cubic storage density: The hexagonal tower architecture converts full building height into usable storage, achieving significantly higher space utilization than floor-based robot systems.
- Independent scalability: Storage capacity and throughput scale separately. Add towers to increase locations. Add robots to increase order rate. No structural redesign required.
- Direct access to every tote: No reshuffling or digging. Every storage position is directly reachable, supporting both high-volume and fine-grained picking operations.
- No in-rack electrification: The passive steel structure requires no embedded motors or cabling, simplifying installation, maintenance, and relocation.
- WMS integration via standard APIs: The Hexxabotics Control System connects to existing warehouse management systems without requiring a full technology replacement.
For industrial automation engineers evaluating high-density storage with scalable throughput, Hexxabotics offers a technically differentiated path beyond what conventional AMR platforms deliver. Learn more about Hexxabotics and explore how the system fits your operational requirements.